Project overview
This project developed a self-stabilizing contactless positioner combining near-field acoustic levitation with planar electromagnetic actuation. Acoustic forces provided vertical lift, stiffness, and squeeze-film damping; the electromagnetic subsystem supplied lateral confinement and programmable multi-axis forces; and an integrated conductive layer provided eddy-current damping.
The completed system demonstrated three-axis linear positioning without active feedback stabilization of the levitation state.
Why the work mattered
Diamagnetic support offered passive stability but limited payload and bandwidth because of weak force and stiffness. Near-field acoustic levitation provided a substantially stronger and controllable source of vertical support, but conventional NFAL had weak lateral confinement and limited multi-axis actuation.
Technical approach
- Comparison and modeling of passive levitation mechanisms
- Two generations of experimental prototypes
- Mechanical-horn design for ultrasonic amplitude amplification
- Stationary multi-zone planar electromagnetic actuation
- Eddy-current damping for horizontal dynamics
- Optical interferometric and image-based displacement measurement
- Real-time electronics, software, and experimental characterization
Selected results
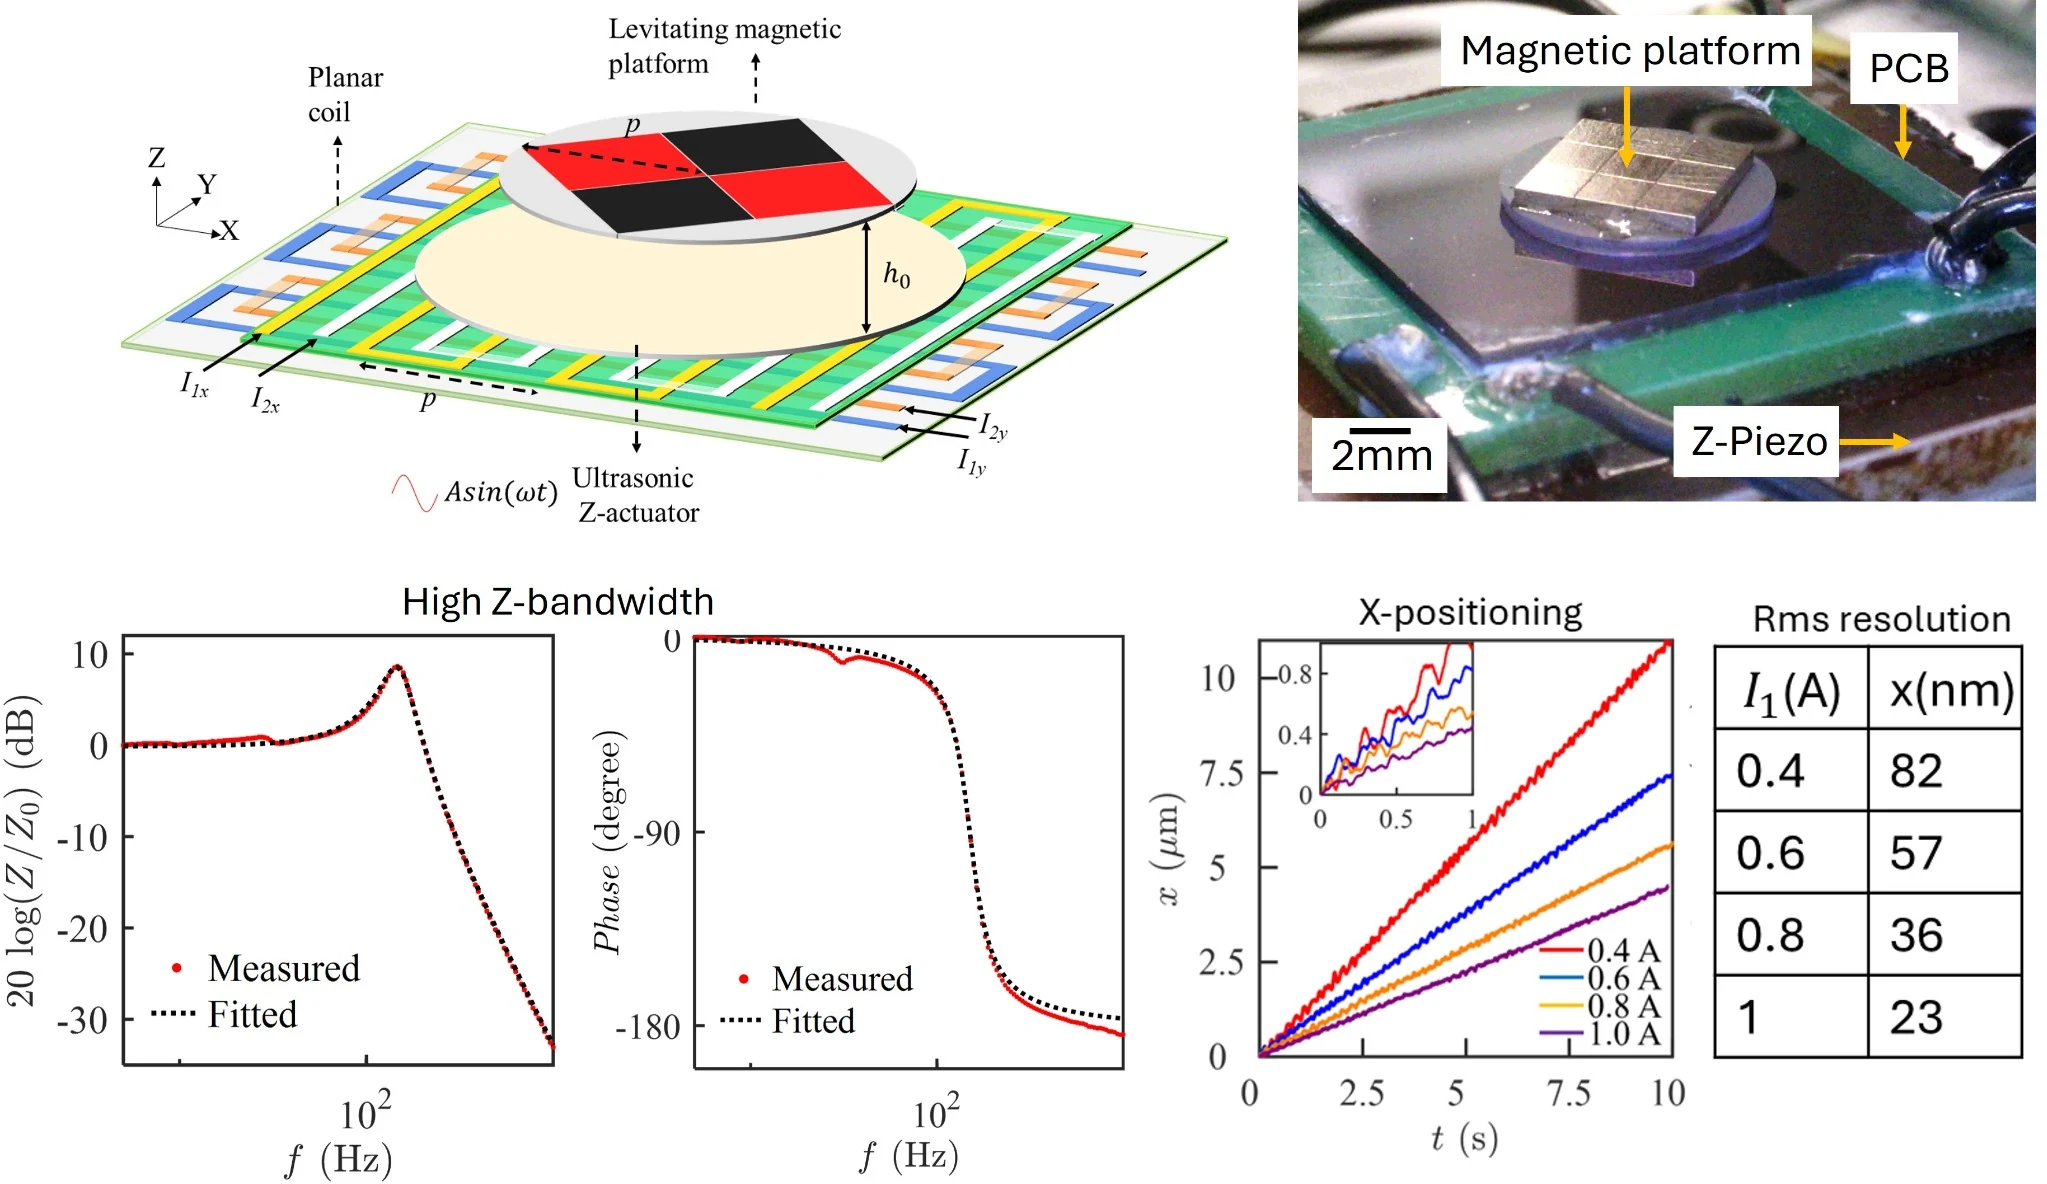
Research leadership and contribution
Dr. Singh conceived and led the hybrid NFAL–electromagnetic nanopositioning program during his postdoctoral research. Motivated by the payload and bandwidth limitations of his earlier diamagnetically levitated stages, he proposed combining the strong passive vertical support of near-field acoustic levitation with programmable planar electromagnetic actuation. He led the modeling, development of two prototype generations, mechanical-horn and multi-zone actuator design, system integration, software development, measurement, experimental characterization, and preparation of the original journal manuscript. Prosanto Biswas contributed during the final experimental and data-analysis phase, Dr. Hazhir Mahmoodi Nasrabadi supported the first proof-of-concept prototype, and Prof. S. O. Reza Moheimani provided guidance and supervision.
Demonstration videos
Unconstrained near-field acoustic levitation
A clear demonstration of an untethered platform levitating above an ultrasonic actuator. The silent video illustrates the passive support principle.
Early-prototype X motion
In-plane electromagnetic motion of an acoustically levitated platform using the first proof-of-concept architecture.
Connection to current PIC Lab research
This project is the direct technical precursor to the current Contactless Multi-Axis Precision Positioning program. The current direction extends the demonstrated three-axis platform toward six-axis motion, microscope- and camera-based feedback, larger workspaces, improved payload and bandwidth, and semiconductor-oriented validation.
Publications
K. S. Vikrant, P. Biswas, and S. O. R. Moheimani, “A Three-Axis Nanopositioner Based on Near-Field Acoustic Levitation and Electromagnetic Actuation,” Sensors and Actuators A: Physical, 394, 116894, 2025.
Initial proof of concept: “A Novel Actuator Based on Near-Field Acoustic Levitation and Electromagnetic Actuation,” MARSS 2023.