Completed projects that form PIC Lab’s technical foundation
These projects were undertaken during Dr. Vikrant Kumar Singh’s doctoral research at IISc Bangalore and postdoctoral research at UT Dallas.
Institutional context: experimental photographs on these pages represent completed work at IISc or UT Dallas and should not be interpreted as current PIC Lab facilities at IIT Kharagpur.
Contactless motion and force metrology
From passive levitation to hybrid positioning
Doctoral research · IISc Bangalore
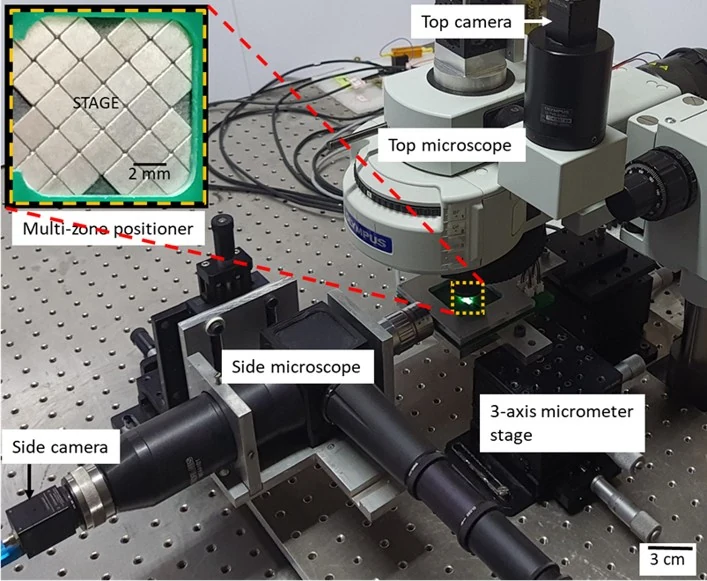
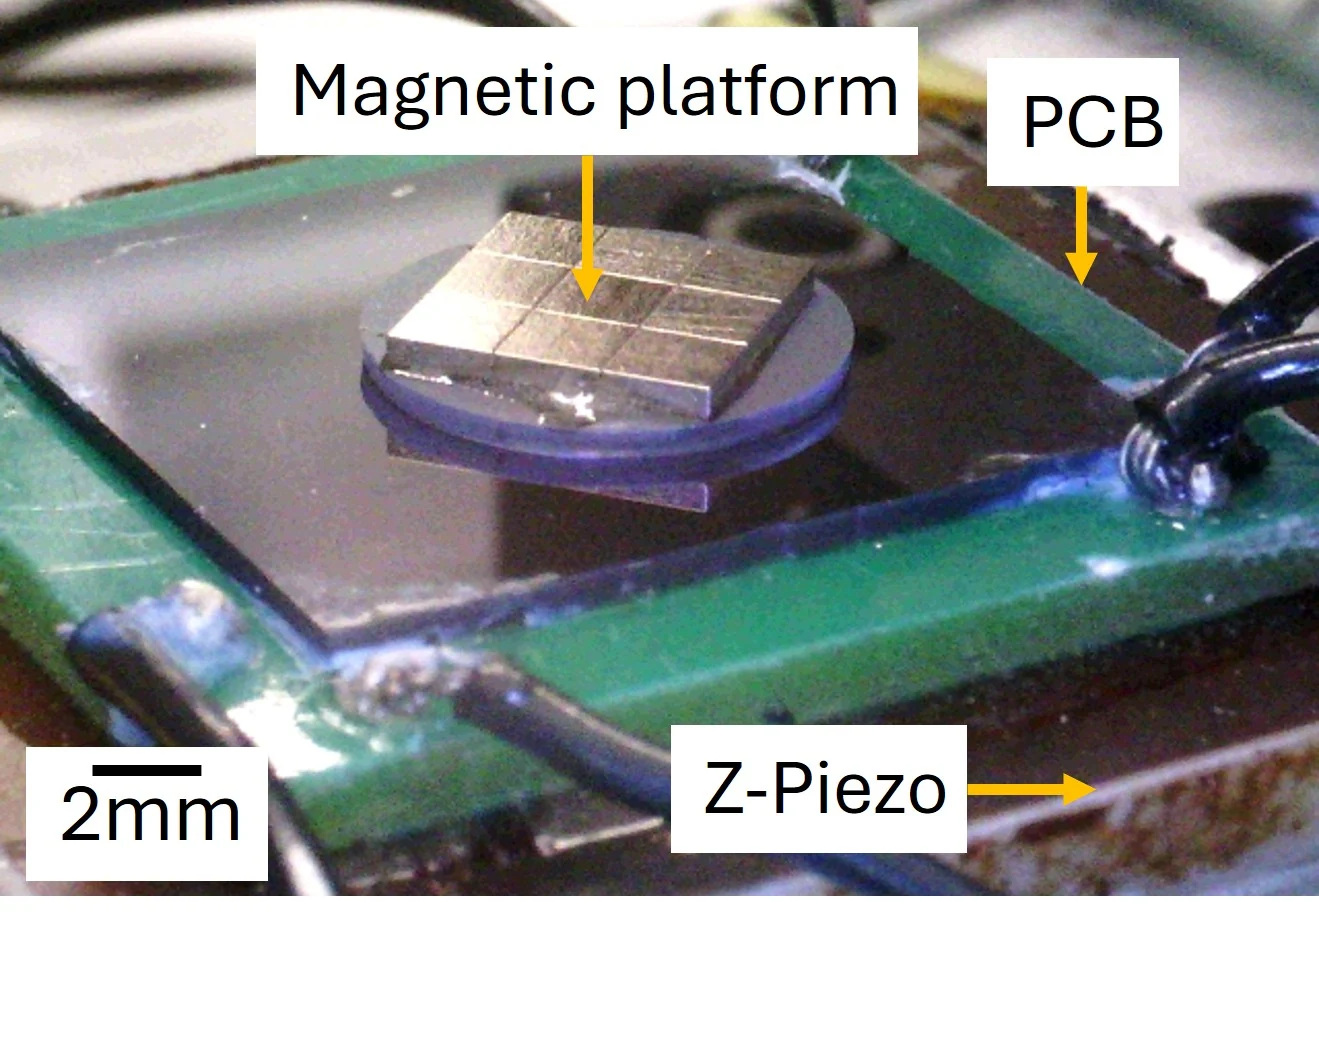
Six-DOF Diamagnetic Nanopositioning
6-DOFmotion
5 mmtravel
<1.88 nmprecision
Postdoctoral research · UT Dallas
Planar EM Actuators & Force Metrology
100×force density
1000×stiffness density
<15%error
Postdoctoral research · UT Dallas
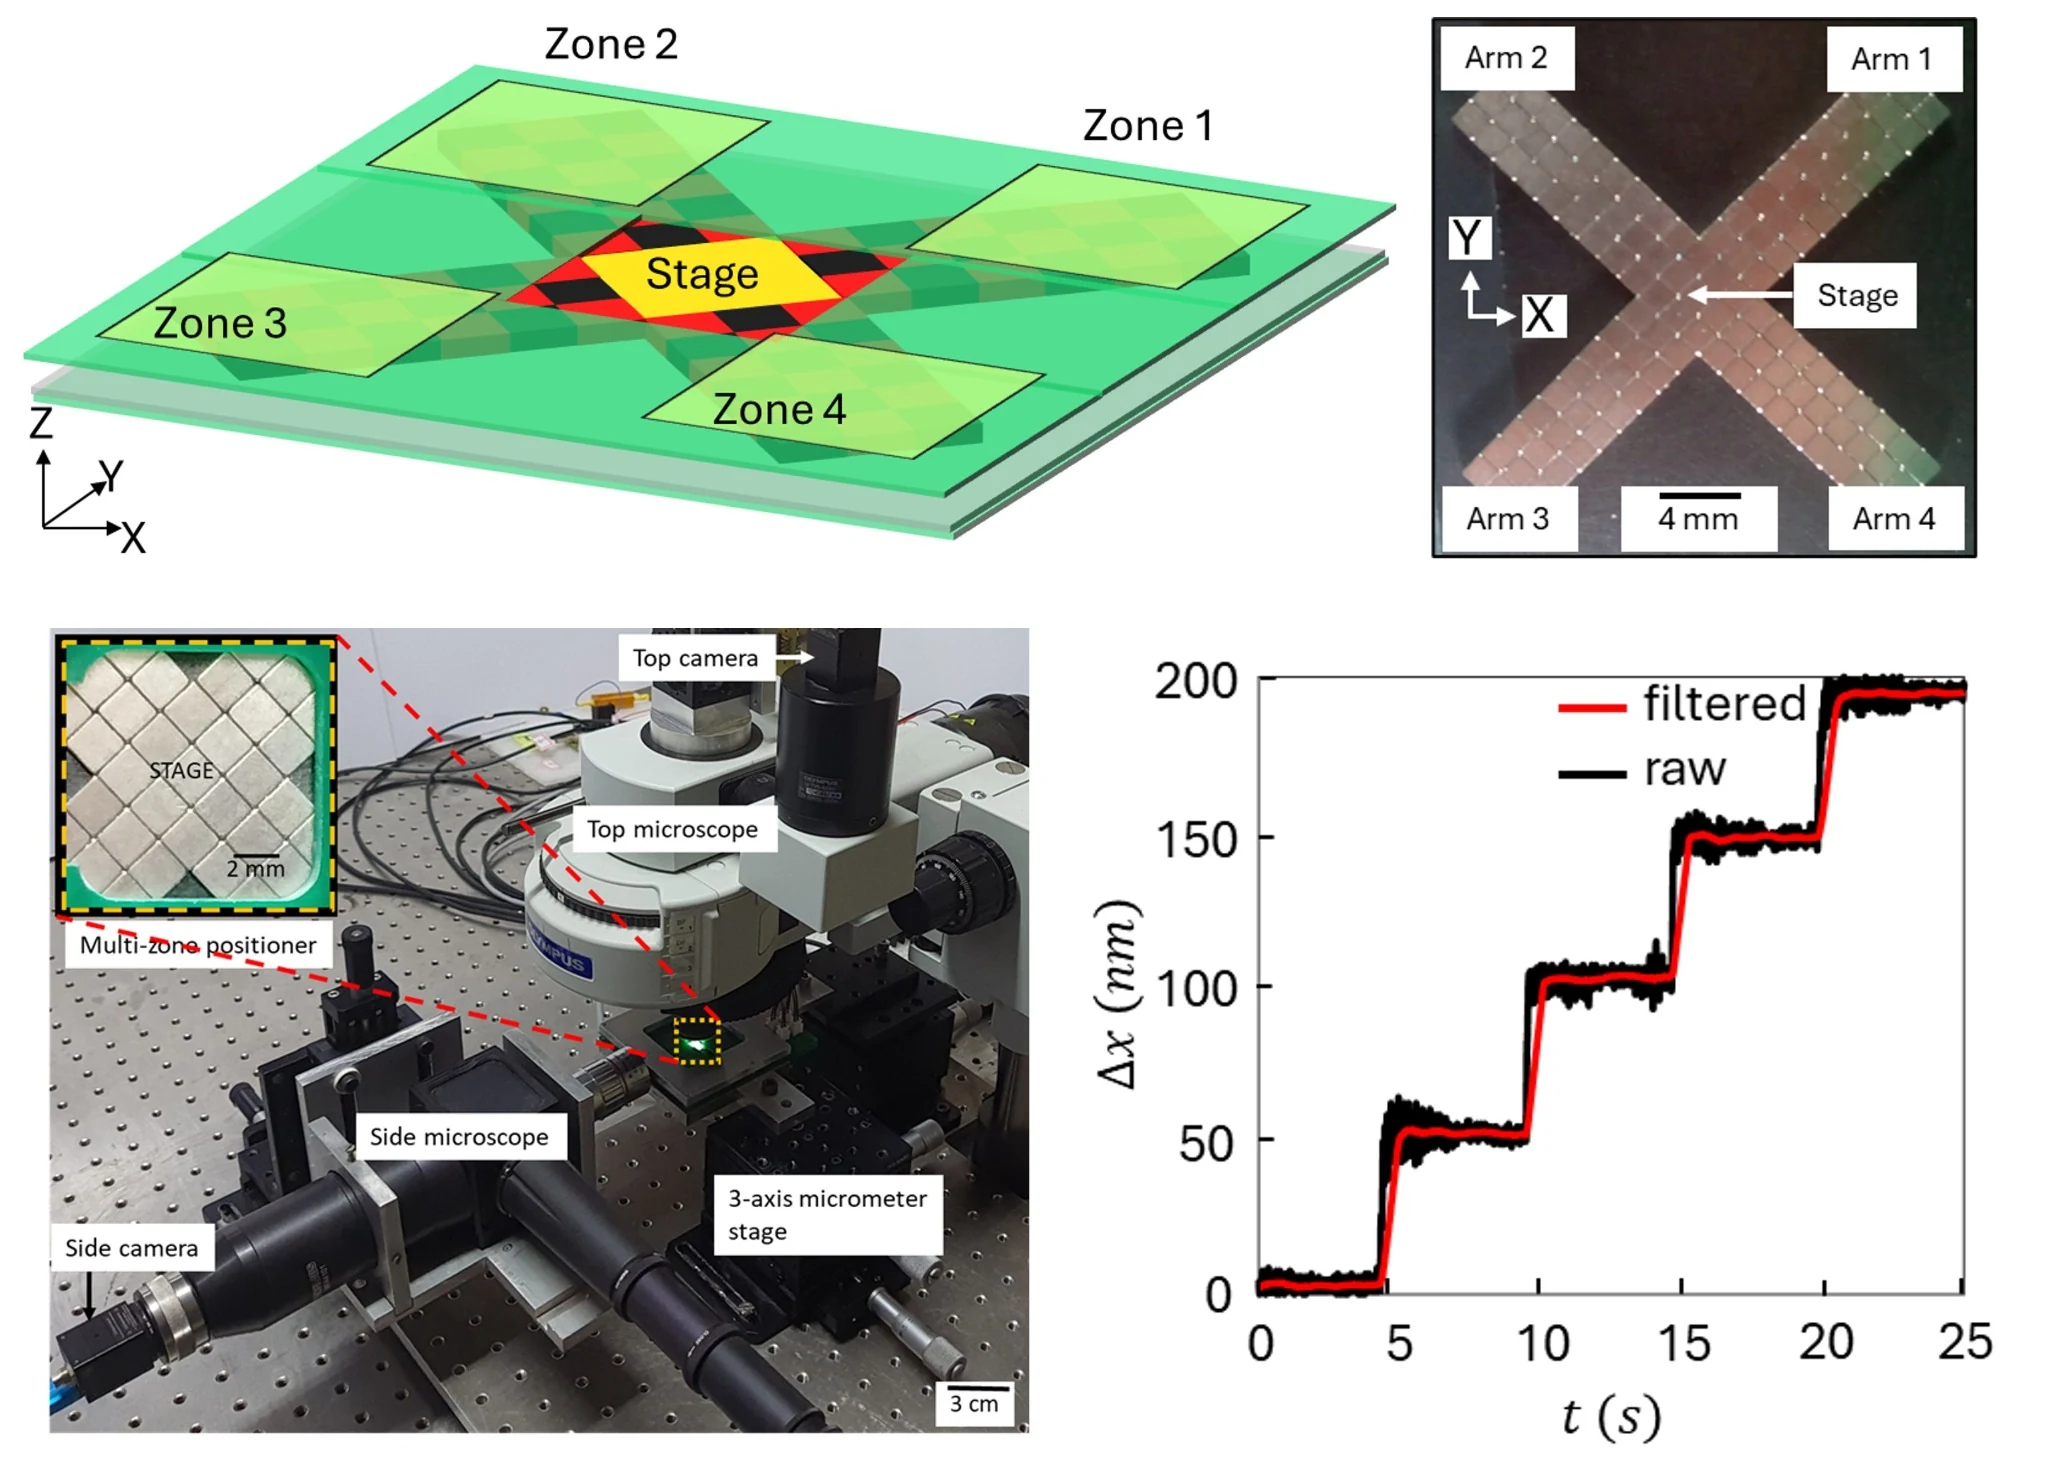
Hybrid NFAL–EM Nanopositioning
<20 nmresolution
1.42 mmXY travel
171 HzZ bandwidth
Automated and parallel AFM
Reducing maintenance and serial-scanning bottlenecks
Doctoral research · IISc Bangalore
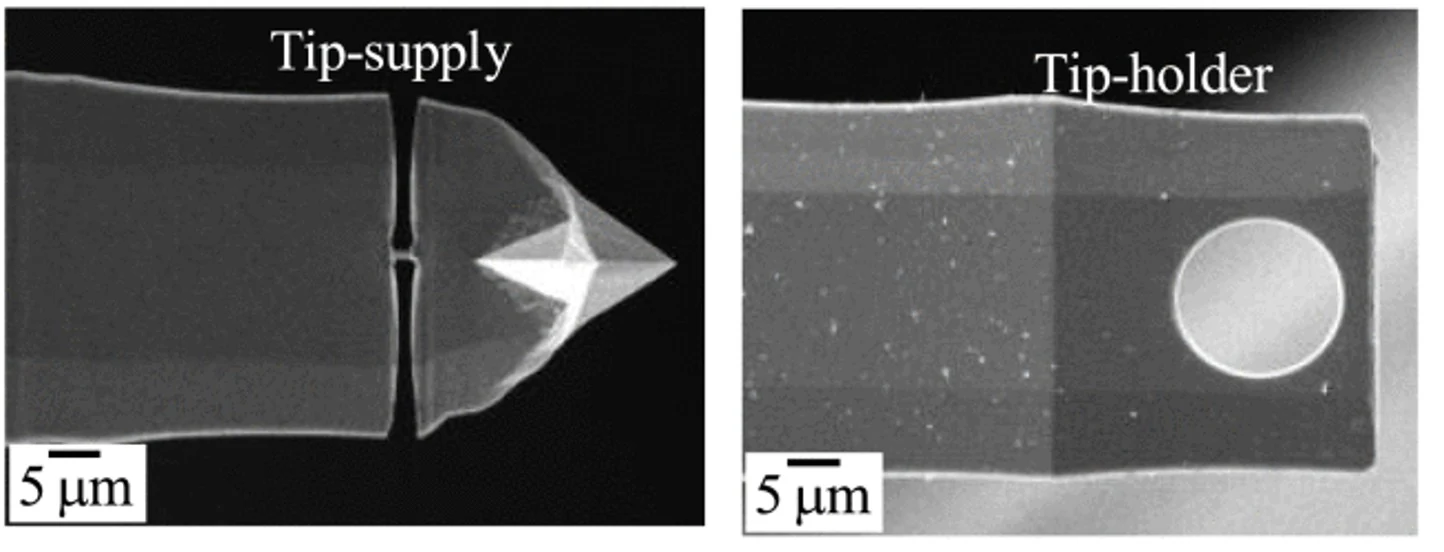
Automated In-Situ AFM Tip Replacement
10 sreplacement
<0.3 µmerror
Restoredimaging
Postdoctoral research · UT Dallas
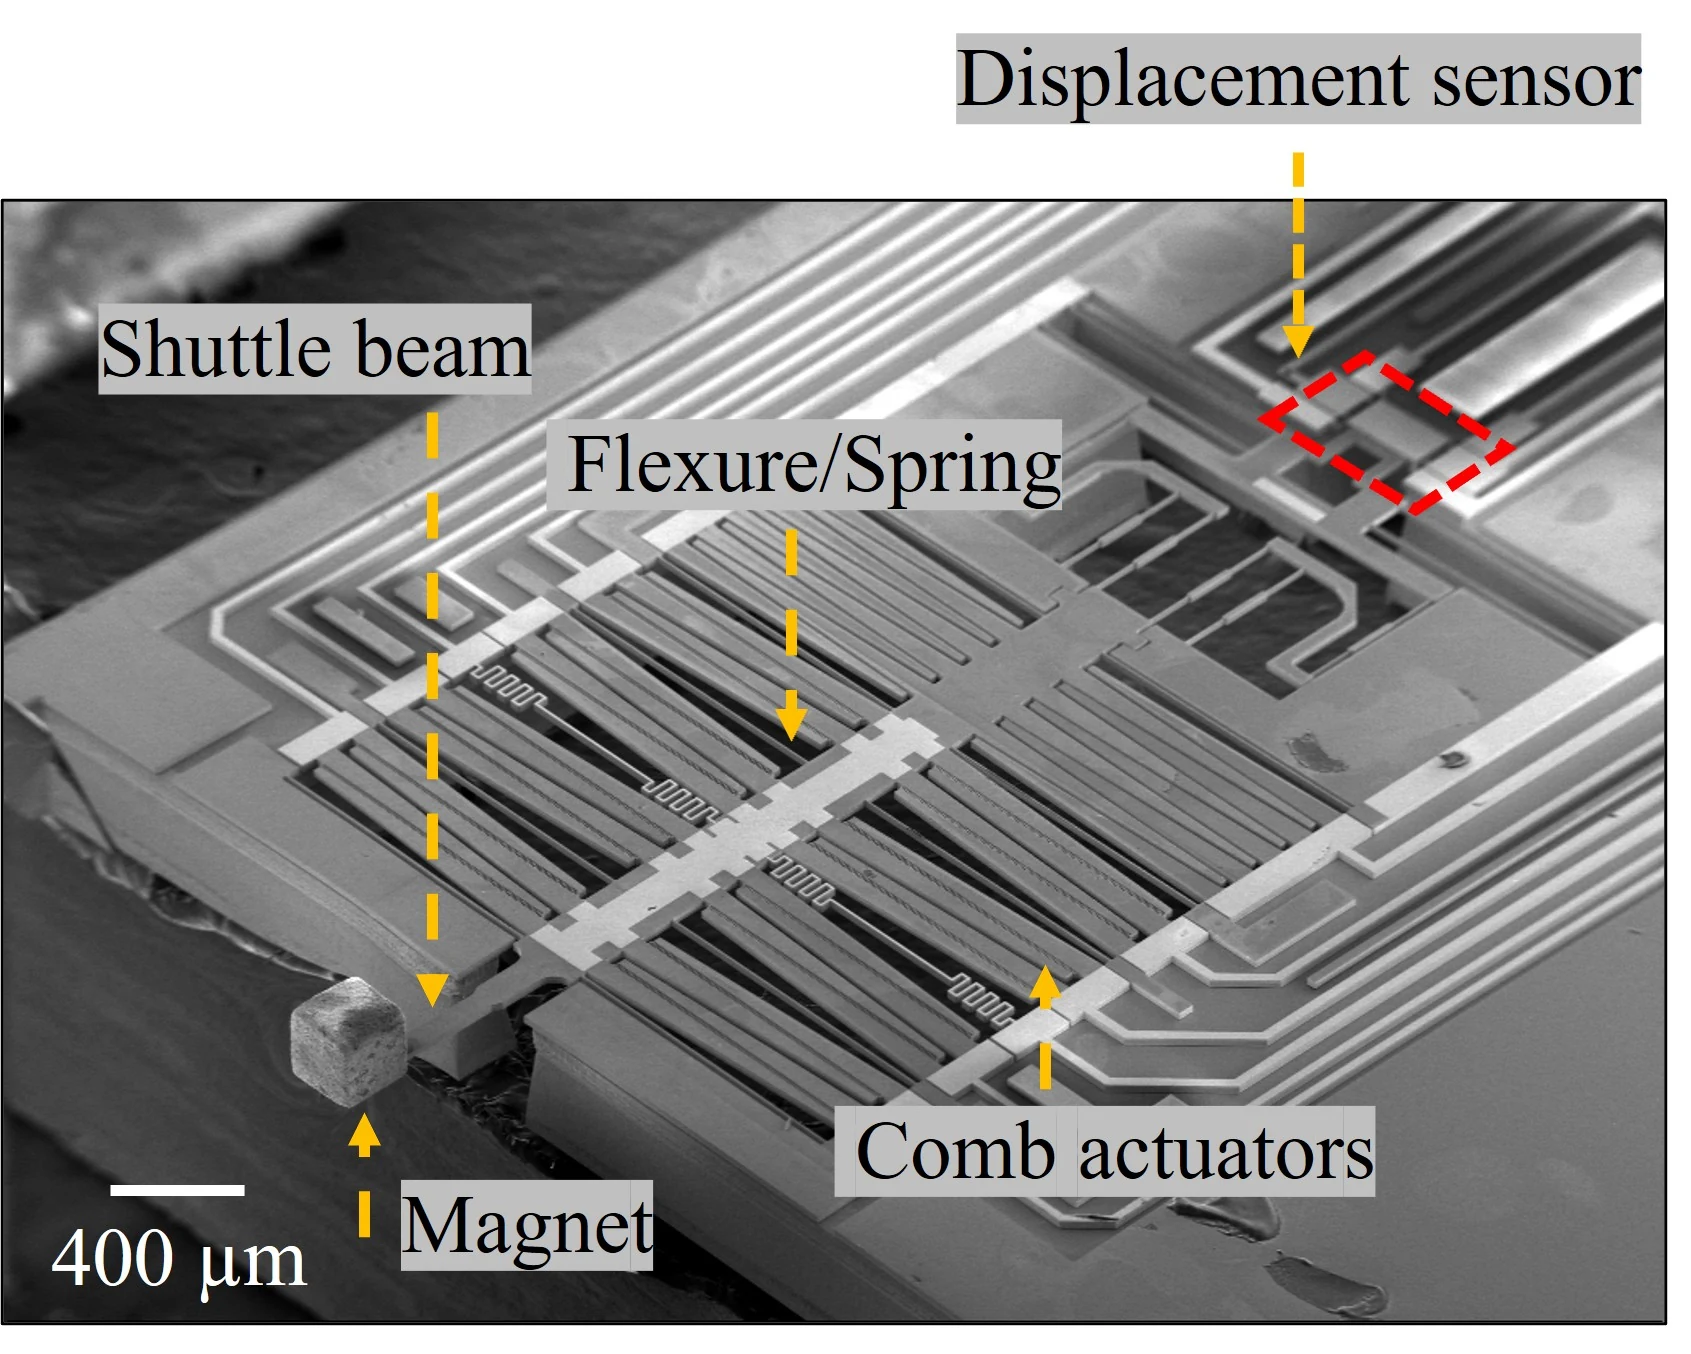
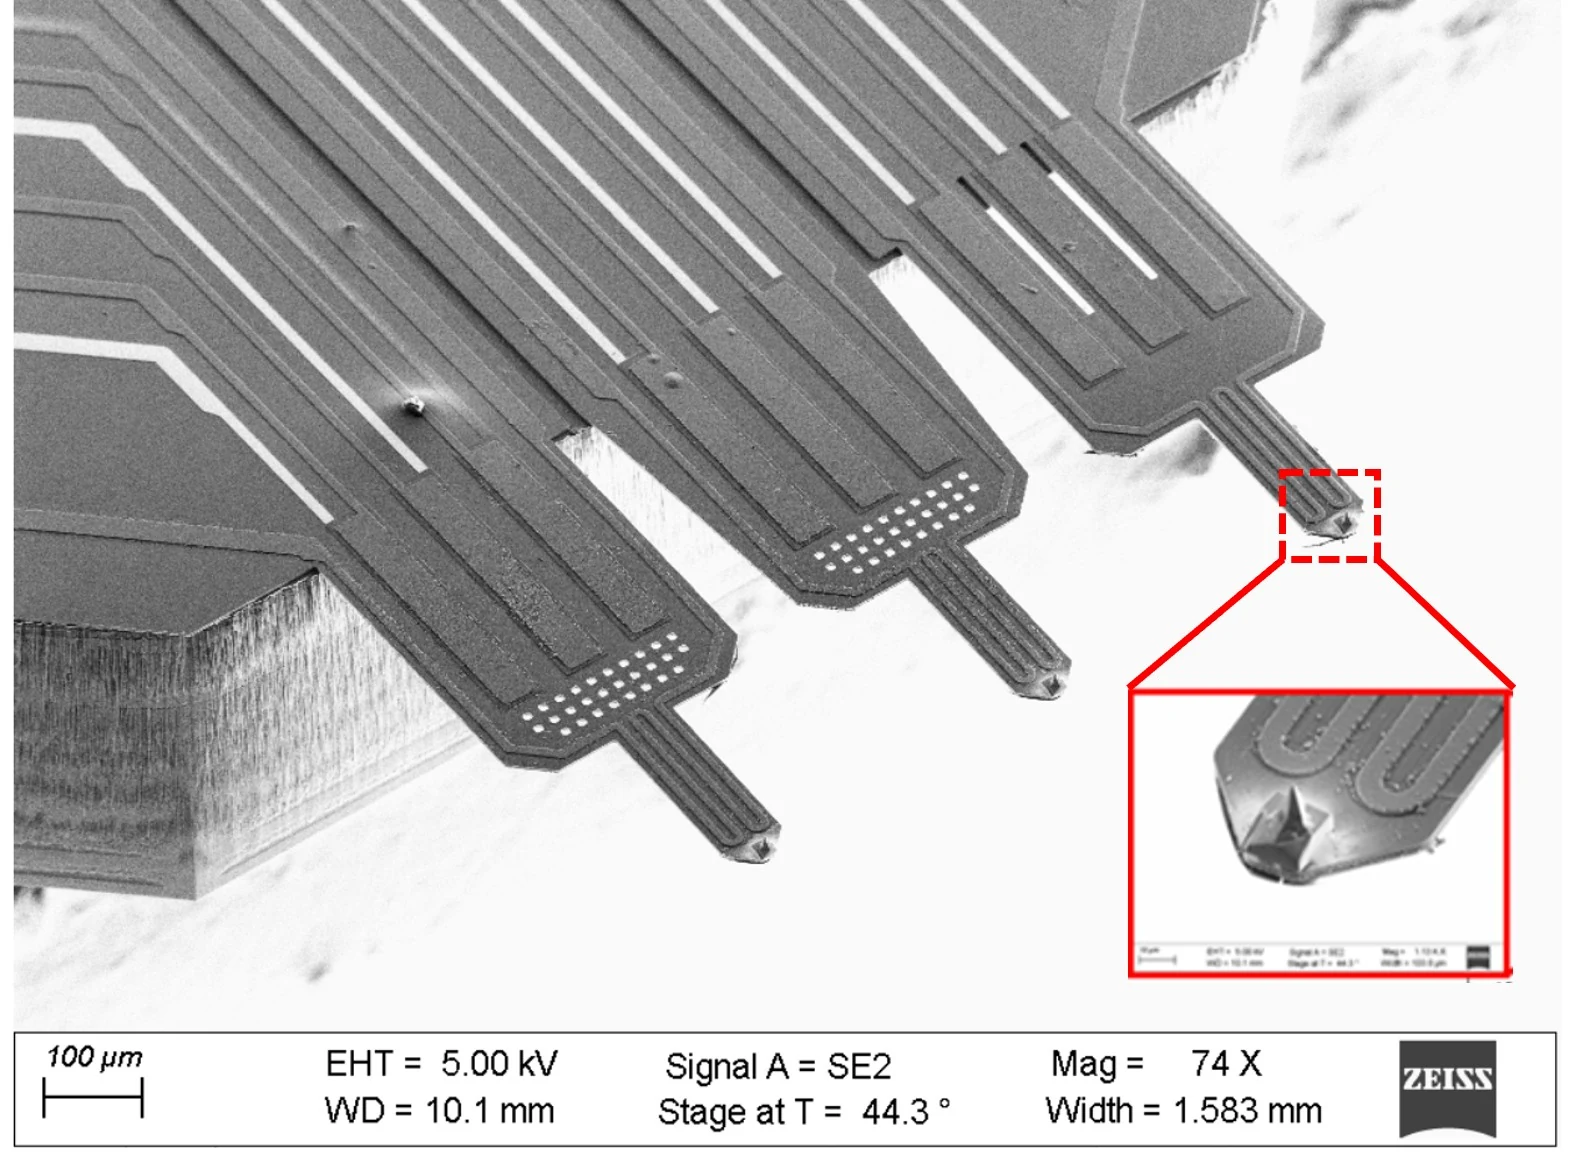
Parallel Active MEMS Microcantilevers
3×throughput
12 nmsampling
10 µmZ range
Research lineage
From completed systems to current PIC Lab directions