Project overview
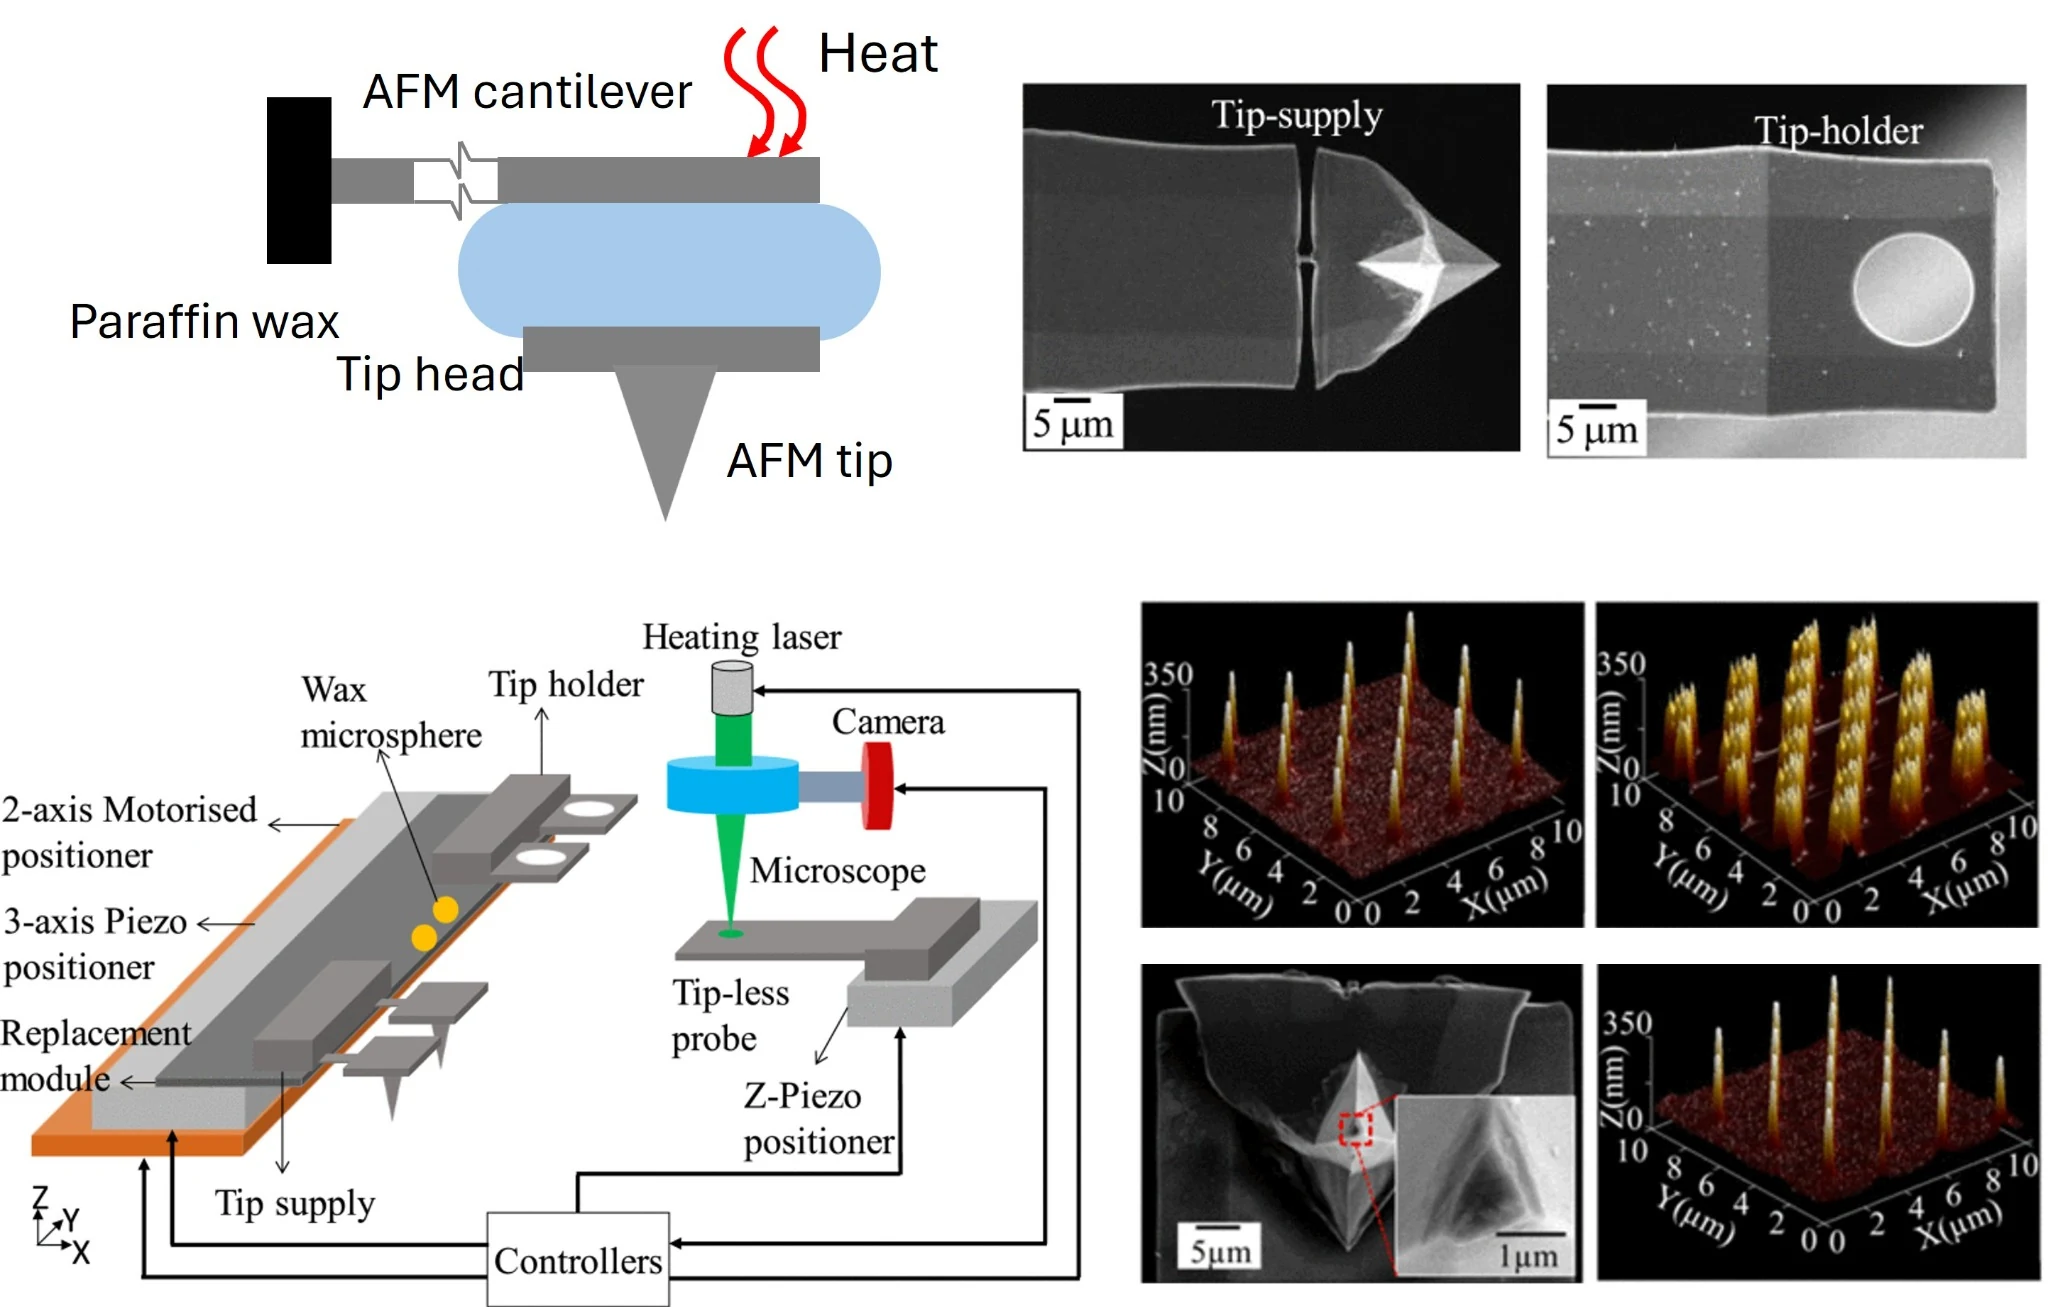
This project developed a vision-guided system that replaces only the worn or damaged tip of an AFM probe rather than discarding the complete cantilever. A phase-change wax microgripper, focused laser heating, hybrid coarse–fine positioning, and automated visual feedback were integrated into a complete tip-exchange instrument.
Why the work mattered
AFM tips become worn, contaminated, or fractured through repeated use and high-force interactions. Replacing only the tip can reduce downtime and cost, retain specialized active cantilevers, avoid unnecessary recalibration, and enable different tip geometries to be exchanged on demand.
Technical approach
- Phase-change paraffin-wax microgripping
- Focused laser heating
- Microfabricated tip-supply and tip-holder stations
- Motorized coarse and piezoelectric fine positioning
- Image-correlation-based in-plane measurement
- Image-blur-based out-of-plane measurement
- Automated docking, pickup, and detachment
- Contact- and tapping-mode AFM validation
Selected results
Research leadership and contribution
Dr. Singh led the system-level design, automation, software development, integration, and experimental validation of the AFM tip-replacement platform. Building on Prof. G. R. Jayanth’s original wax-microgripper concept, he conceived the focused-laser phase-control and vision-guided automation strategies, developed the coarse–fine positioning and control system, and performed the experiments demonstrating rapid and repeatable tip exchange. Wax microsphere preparation was contributed by K. Hithiksha.
Connection to current PIC Lab research
This project established expertise in automated micro-assembly, visual-feedback control, coarse–fine positioning, optical phase control, and complete scientific-instrument integration. These capabilities support the current Parallel Atomic Force Microscopy program, where scalable operation will require probe alignment, calibration, maintenance, and replacement.
Publication
K. S. Vikrant, K. Hithiksha, and G. R. Jayanth, “An Automated AFM Tip-Replacement System for In Situ Tip-Replacement,” IEEE/ASME Transactions on Mechatronics, 26(2), 798–806, 2021.
Related precursor: K. S. Vikrant and G. R. Jayanth, “An AFM Tip Replacement System Compatible with All Ambient Media and Operation Modalities,” Ultramicroscopy, 196, 136–141, 2019.